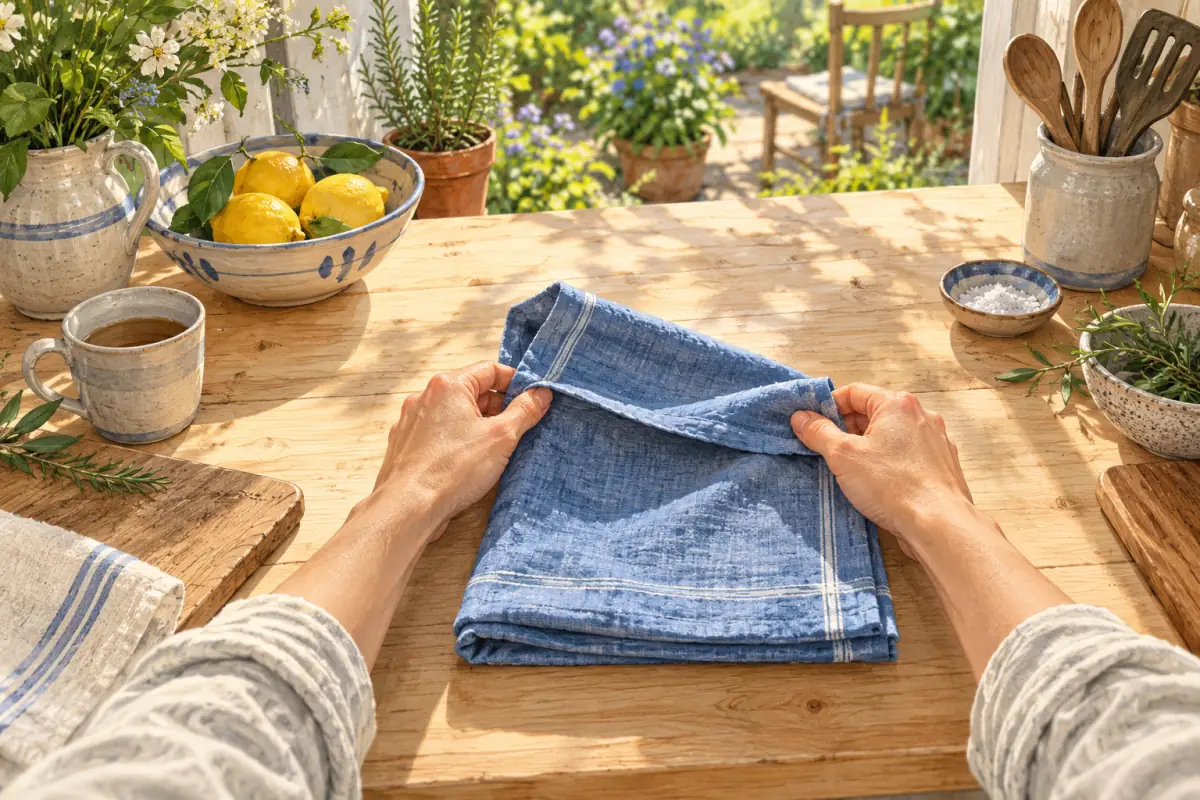
What is egocentric data for robot learning?
Egocentric data explained: what first-person video captures, how it differs from robot action data and what to check before using it for robot learning.
Wake guides
Egocentric data explained: what first-person video captures, how it differs from robot action data and what to check before using it for robot learning.
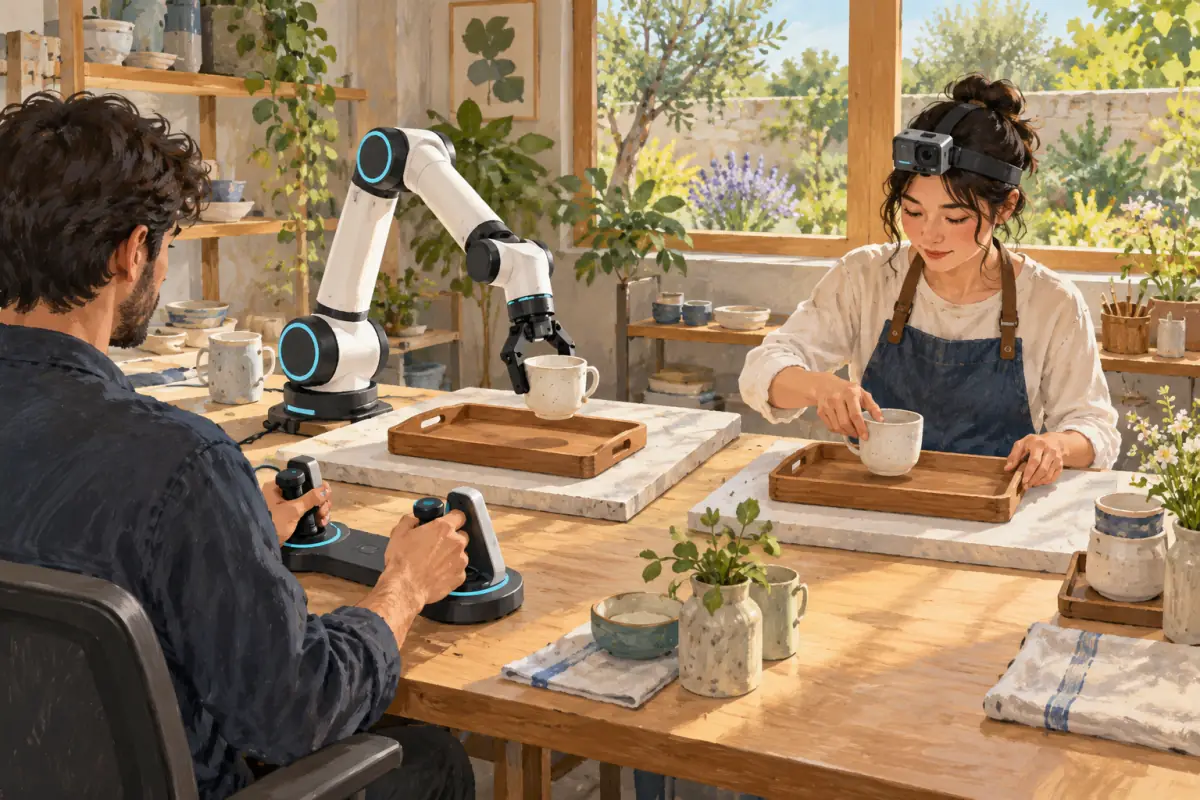
Compare teleoperation data and egocentric human video for robot learning: observations, actions, embodiment, collection constraints and evaluation.
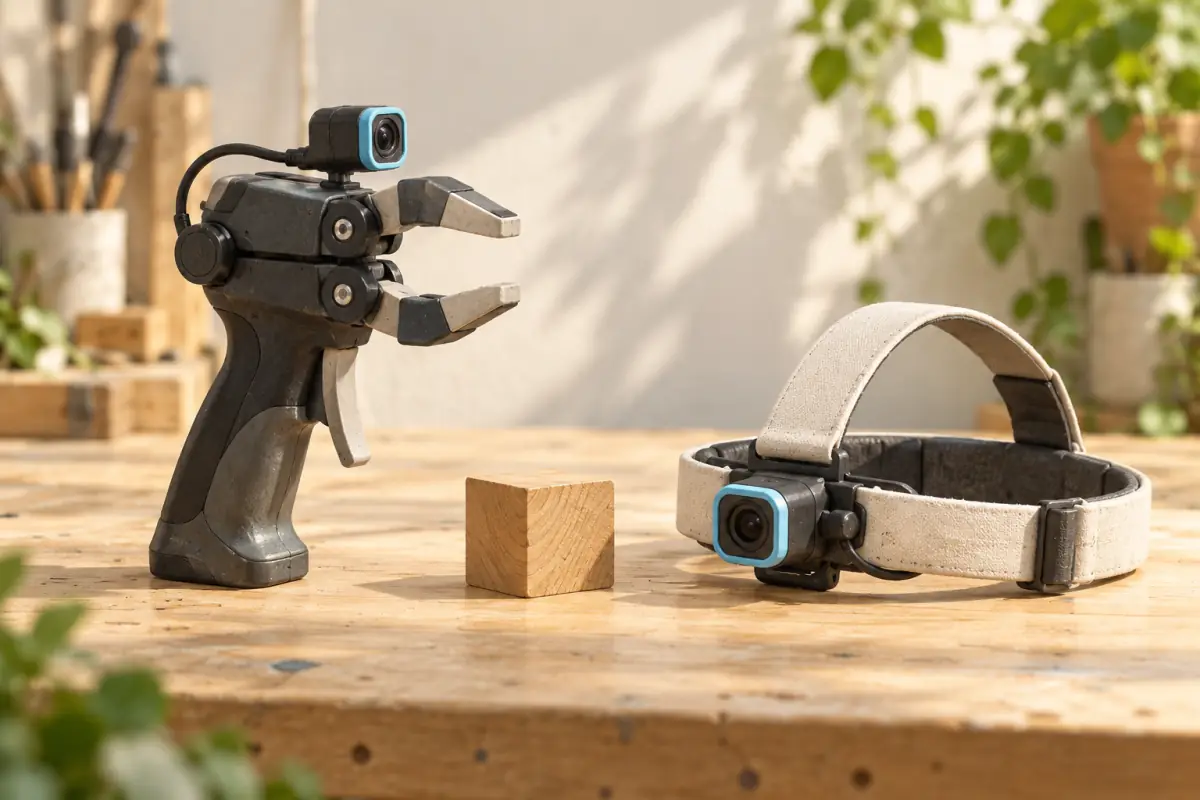
Understand UMI gripper demonstrations and head-mounted video: captured signals, task fit, viewpoint limitations and questions for a robotics data brief.
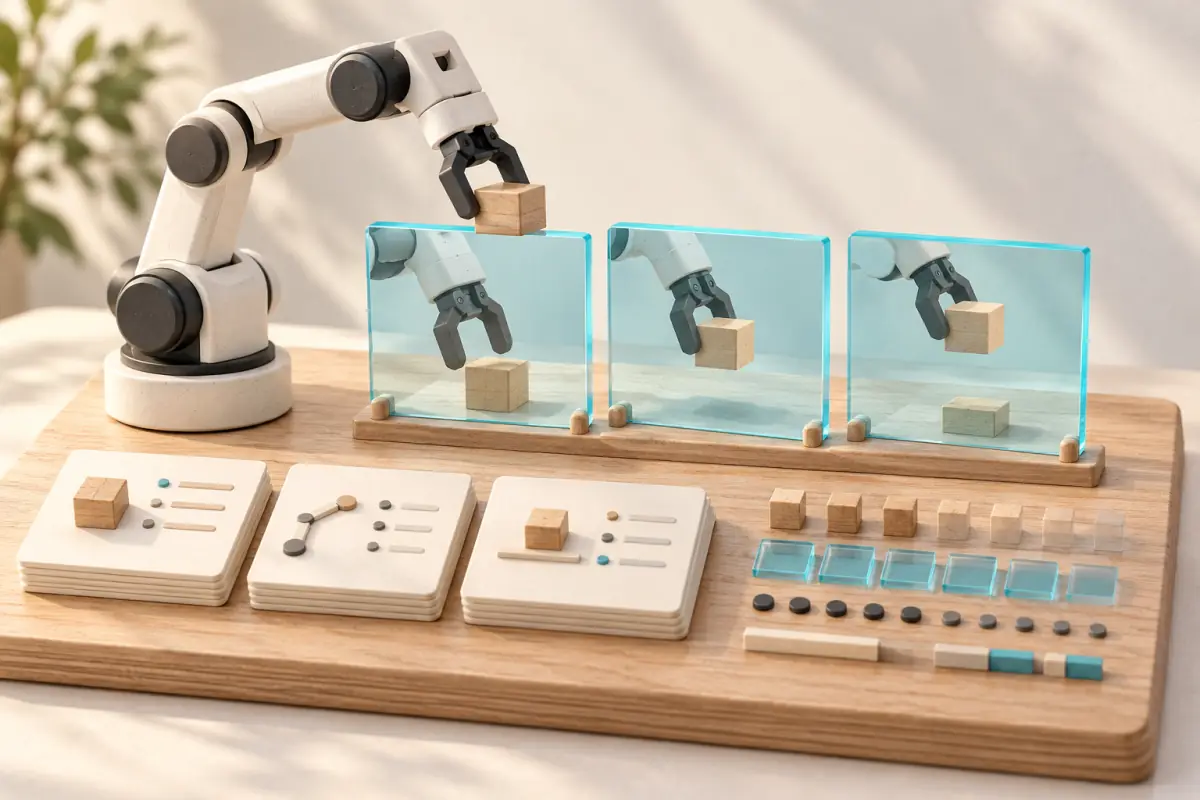
A practical guide to LeRobot dataset structure, episode metadata, video alignment and validation, with distinctions from HDF5 and RLDS.
Bring the task, setting and signals you need. We’ll work through the collection and annotation requirements with you.