Egocentric video
Hands, tools and context from the worker’s view.
Scope: Viewpoint, visibility and scene variation.
For robotics labs
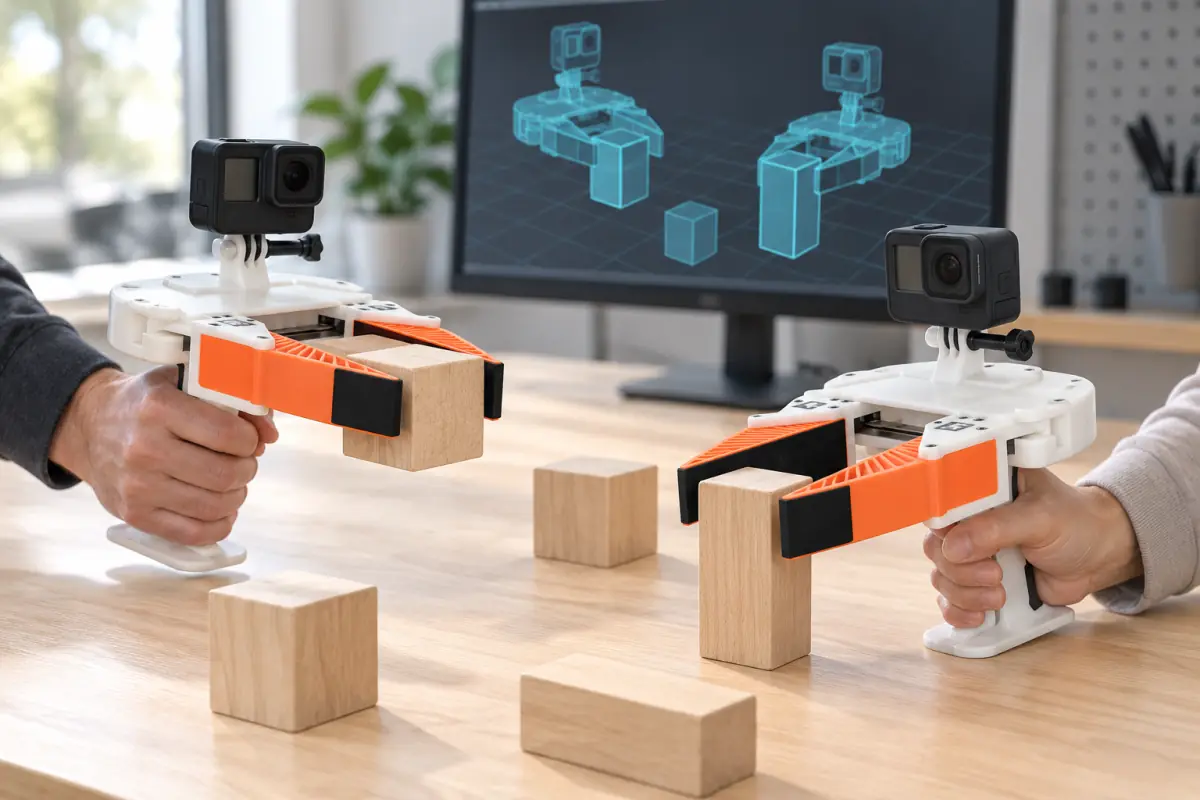
Robotics data collection starts with the signal your model needs.
Hands, tools and context from the worker’s view.
Scope: Viewpoint, visibility and scene variation.
A task shown from setup to outcome.
Scope: Instructions, action steps and recovery.
Robot observations and commands during human control.
Scope: Embodiment, actions and synchronized signals.
Agree the specification before egocentric data collection begins.
Agree the fields and label definitions your project needs.
LeRobot, HDF5 and RLDS are requirements to scope, not verified integrations. Conversion cannot create unrecorded robot actions.
Dataset version, features, camera keys and action representation.
Groups, shapes, types, units and compression.
Observations, actions, step flags and episode metadata.
Robot training data contains observations, demonstrations, instructions and, where recorded, actions for training or evaluating robot models. The required signals depend on the task and robot.
No. Egocentric video records a person’s view. Robot actions need separately measured signals or a justified mapping.
Yes. Include the format and loader version in your inquiry. Wake scopes available fields and compatibility before agreeing delivery.
Share the task and data requirements. Start here or use our contact form.
Format references: Hugging Face: LeRobotDataset v3.0 · Google Research: RLDS data model